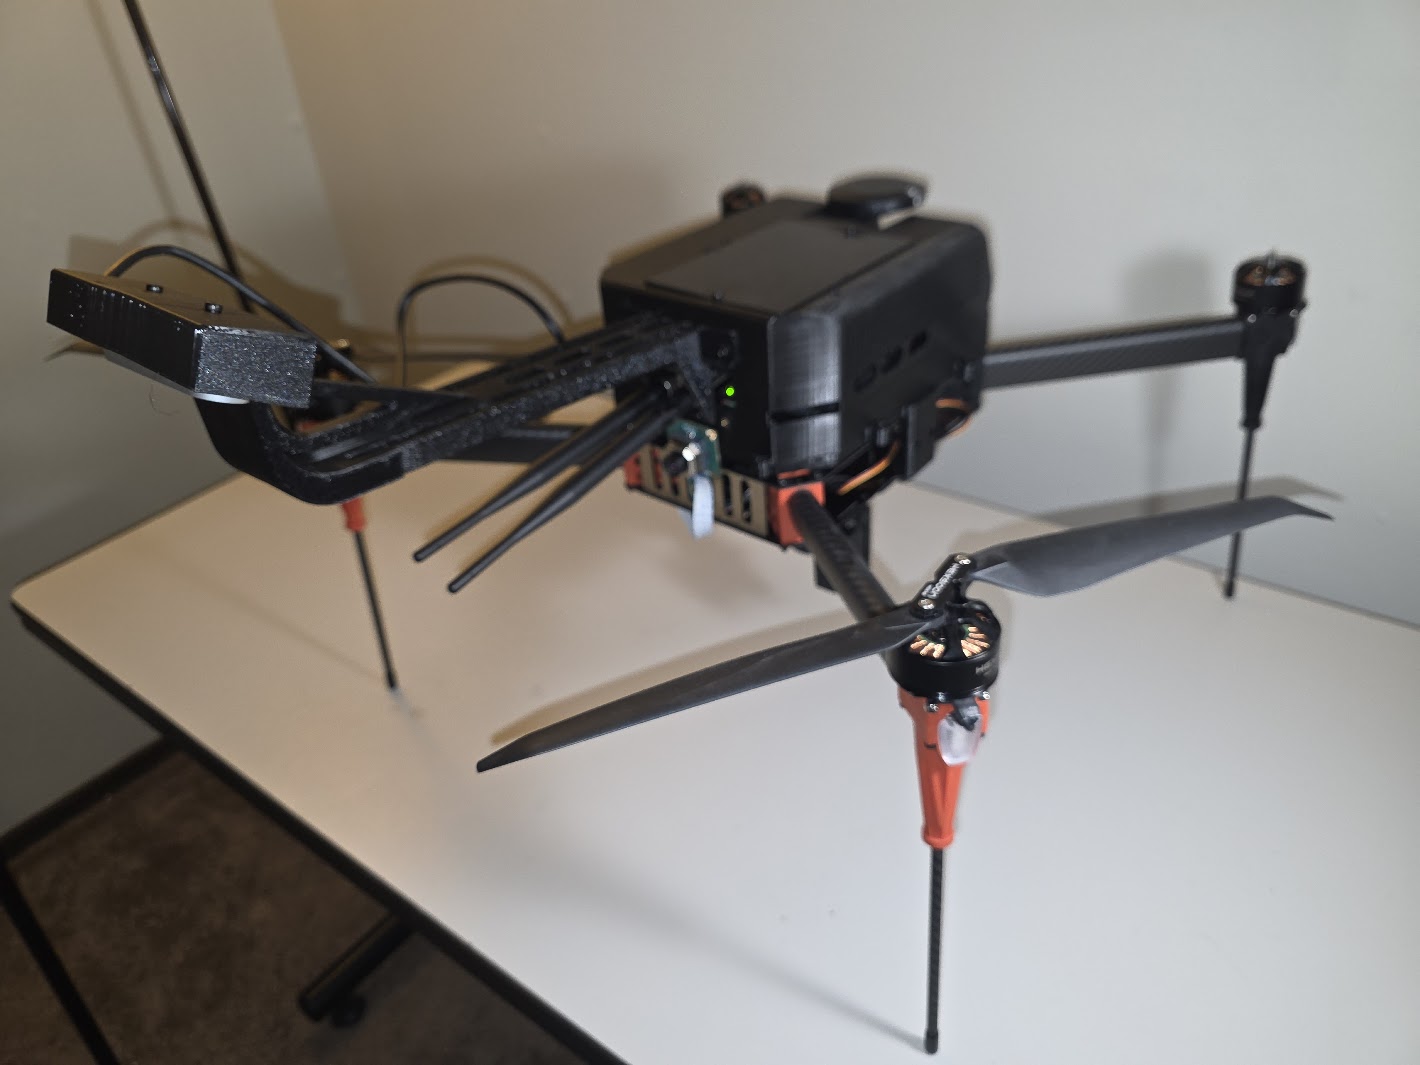
Building autonomous drone systems for infrastructure inspection.
Key Contributions
- Engineered Isaac ROS Visual SLAM pipeline on NVIDIA Jetson Orin with Intel RealSense D435I for real-time 3D mapping
- Developed MAVLink-based flight control system integrating Jetson with CubePilot Orange autopilot
- Built WebRTC video streaming system for real-time sensor data transmission
- Implemented ROS 2 servo control with PCA9685 PWM drivers
- Fine-tuned YOLO for power line anomaly detection on edge devices