Araas Boloorchi, Ph.D.
Principal Perception Engineer — 3D Vision, Depth Sensing & Robot Autonomy
Summary
Perception and robotics engineer with a Ph.D. in Computer Science and 8+ years building autonomous robots — from Nao humanoids and vision-guided drones in GPS-denied environments to depth-based perception for robotic tire automation. Deep expertise in 3D reconstruction, depth sensing, SLAM, visual-inertial odometry, object detection, and sim-to-real transfer with NVIDIA Isaac. Currently leading perception work at Automated Tire, Inc., on a robotic platform that services tires without removing the wheel.
Core Competencies
- Perception & 3D Vision
- Depth cameras & sensor benchmarking, 3D reconstruction, depth estimation, stereo vision, camera calibration, object detection (YOLOv8, MMDetection), OpenCV, industrial vision systems
- Robotics & Autonomy
- ROS 2, SLAM, visual-inertial odometry, sensor fusion, Kalman filtering, reinforcement learning, motion planning, MAVLink, autonomous drones (UAV)
- Machine Learning
- PyTorch, TensorFlow, CNNs, GNNs, ML pipelines, CI/CD, model lifecycle management
- Simulation & Sim-to-Real
- NVIDIA Isaac Sim, Isaac Lab, NVIDIA Replicator, PhysX, domain randomization, synthetic data generation
- Languages
- Python, C++, Go, CUDA, TensorRT, Java
- Hardware & Deployment
- Depth & 3D cameras (Intel RealSense, Stereolabs ZED, Orbbec, Time-of-Flight), NVIDIA Jetson (Orin/Nano), edge inference, real-time robot control
Professional Experience
Principal Perception Engineer
May 2026 – PresentAutomated Tire, Inc. — Woburn, MA
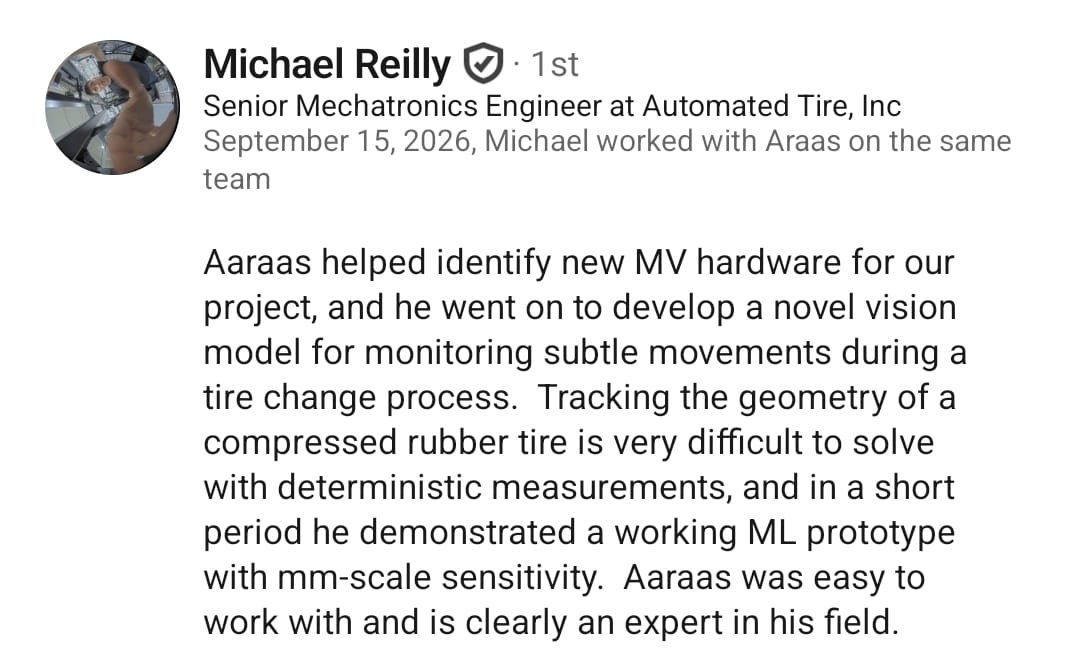
A quick understanding, not a deep dive. The platform is proprietary, so specifics stay inside the company. This is the high-level shape of the work.
- Lead perception engineering: sensor selection, algorithm development, and on-robot deployment
- Evaluate and select depth and machine vision hardware for the platform
- Develop vision models that track a compressed tire's geometry during the tire change, with millimetre-scale sensitivity
- Optimise perception to run in real time on the robot
Machine Learning Engineer (Robot Autonomy)
May 2025 – May 2026FlyX Technologies — Sunnyvale, CA
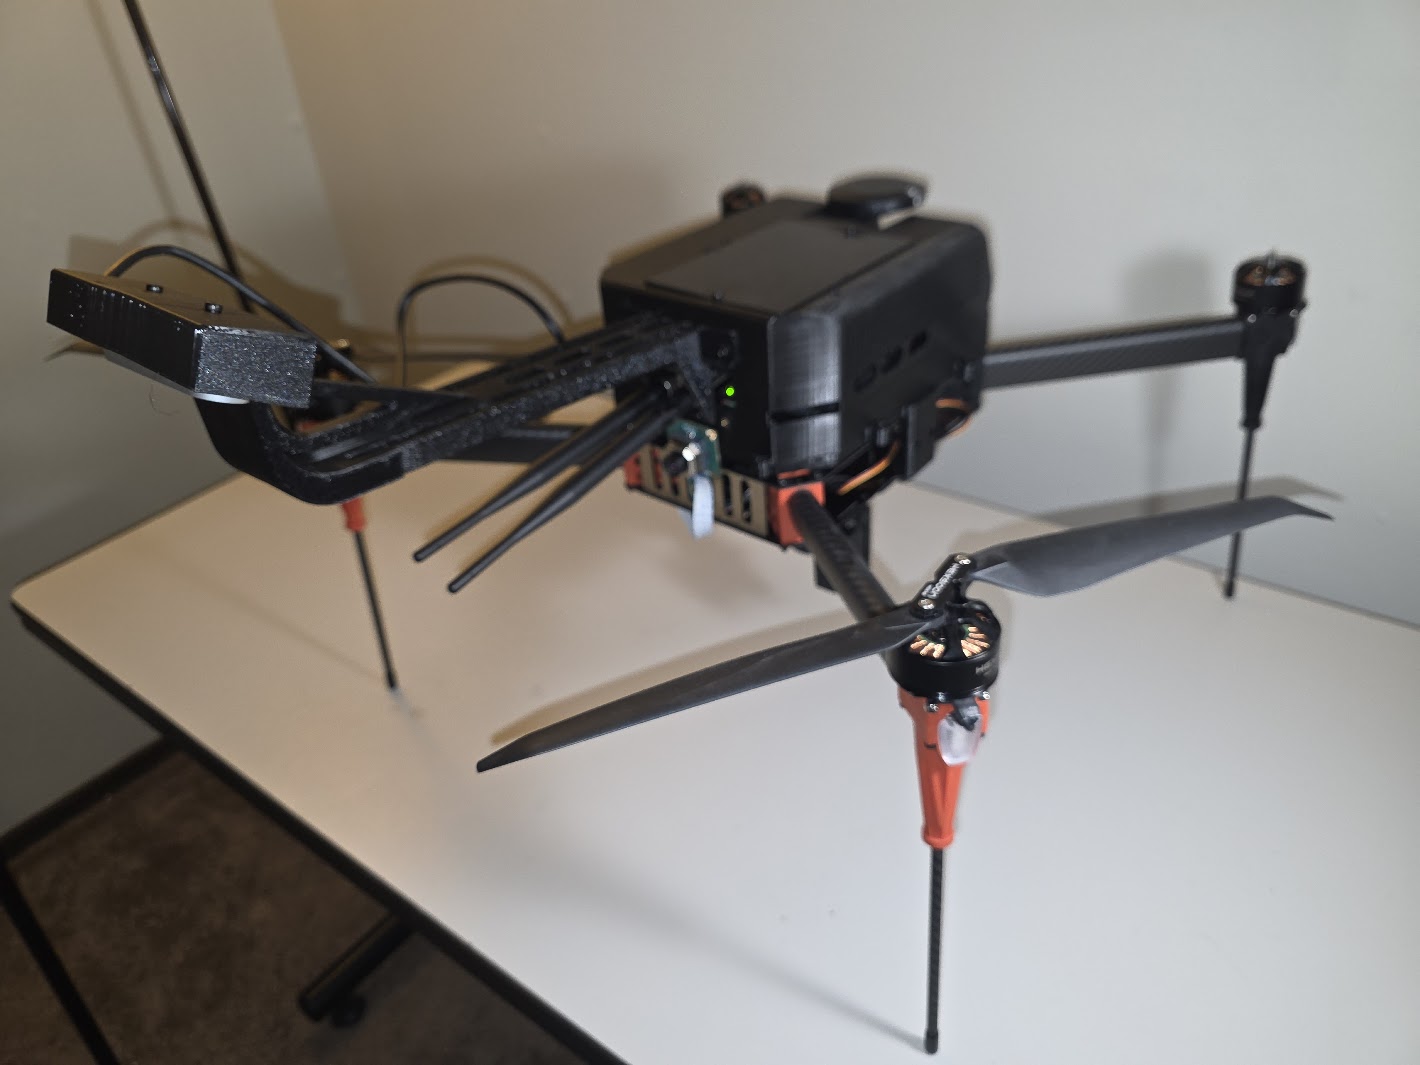
- Built autonomous drones that land on power lines using RL policies trained in NVIDIA Isaac Lab with PhysX contact dynamics, carried from simulation to real flight
- Isaac ROS cuVSLAM on Jetson Orin with RealSense D435i — real-time 3D SLAM and localisation at 25 FPS for GPS-denied outdoor navigation
- Extended cuVSLAM with improved IMU–camera fusion, cutting drift 40% and taking it from prototype to production on UAVs
- MAVLink flight control linking Jetson Orin to CubePilot Orange: bidirectional telemetry, RC override, real-time IMU visualisation
- High-fidelity Isaac Sim environments with Replicator and domain randomisation for large-scale synthetic training data
- ROS 2 servo control with PCA9685 PWM for gimbal manipulation; fine-tuned YOLO for aerial detection on edge devices with a CI/CD deployment pipeline
Co-Founder & Senior Machine Learning Engineer
Jan 2024 – Present (Advisor since May 2026)Catch Up AI — San Francisco, CA
- Co-founded the company and led a 4-engineer ML team from concept to production MVP in 12 weeks, establishing ML pipelines, model lifecycle management and CI/CD; secured initial customer pilots
- Architected a multi-modal pipeline with distributed cloud inference, improving precision from 0.71 to 0.86
- PyTorch GNN modelling social interaction graphs, lifting recommendation accuracy 22%
Machine Learning Researcher
May 2023 – Apr 2024ILead Lab — Stillwater, OK
- CV algorithm (OpenCV, scikit-learn) for automated statistical chart interpretation: 94% detection accuracy, 91% user-rated interpretability
- Explainable AI system with full inference traceability, feeding research on interpretable perception
- Augmentation and architecture tuning (Keras/TensorFlow) raised detection recall 7%
Computer Vision Engineer
May 2022 – Aug 2022Sanborn — Colorado Springs, CO
- Fine-tuned a stereo depth estimation model, cutting inference latency 30% via TensorRT/CUDA without losing accuracy
- End-to-end 3D reconstruction pipeline with production-grade stereo calibration for outdoor deployment, improving perception accuracy 15%
Computer Vision Engineer
May 2020 – Sep 2020General Electric — Oklahoma City, OK
- Shipped an end-to-end industrial vision system for automated defect detection in manufacturing, at 88% F1 with model lifecycle management
- Integrated camera selection, lighting optimisation and environmental adaptation for robust perception in unstructured industrial settings
Research Engineer (Autonomous Drone Navigation)
May 2018 – Aug 2019Advanced Technology Research Center (ATRC) — Stillwater, OK
- Novel sensor fusion methodology for visual-inertial odometry integrating camera and IMU data under US Air Force funding, reducing computational complexity 5% while holding localisation precision
- Real-time SLAM prototype for GPS-denied drone navigation in adversarial outdoor conditions
Robotics Researcher (Humanoid Robots)
Sep 2014 – Mar 2016Mechatronics Research Lab
- Programmed Nao humanoids for the RoboCup Soccer World Cup: autonomous bipedal locomotion, real-time perception and multi-agent coordination in dynamic, unstructured environments
- Computer vision and sensor-driven decision-making for object tracking, obstacle avoidance and team-based manipulation
Education
Ph.D. and M.S., Computer Science
Oklahoma State University
Dissertation: Explainable AI in Visual Odometry and Generative AI for Navigation of Autonomous Drones
Publications
- Towards Responsible AI: Integrating Explainability and Social-Cognitive Frameworks in AI Systems Springer Nature — AI Perspectives & Advances, Jan 2025
- Brain-Inspired Visual Odometry: Balancing Speed and Interpretability Through a System of Systems Approach IEEE CSCI, Dec 2023
- Enhancing ProteinBERT: Integrating Intrinsically Disordered Proteins for Comprehensive Proteomic Predictions IEEE BIBM, Dec 2023
Selected Projects
- Autonomous Drone Navigation System
ATRC, Dec 2019
Turned a conceptual VIO methodology into a real-time navigation device with custom sensor fusion software for GPS-denied flight.
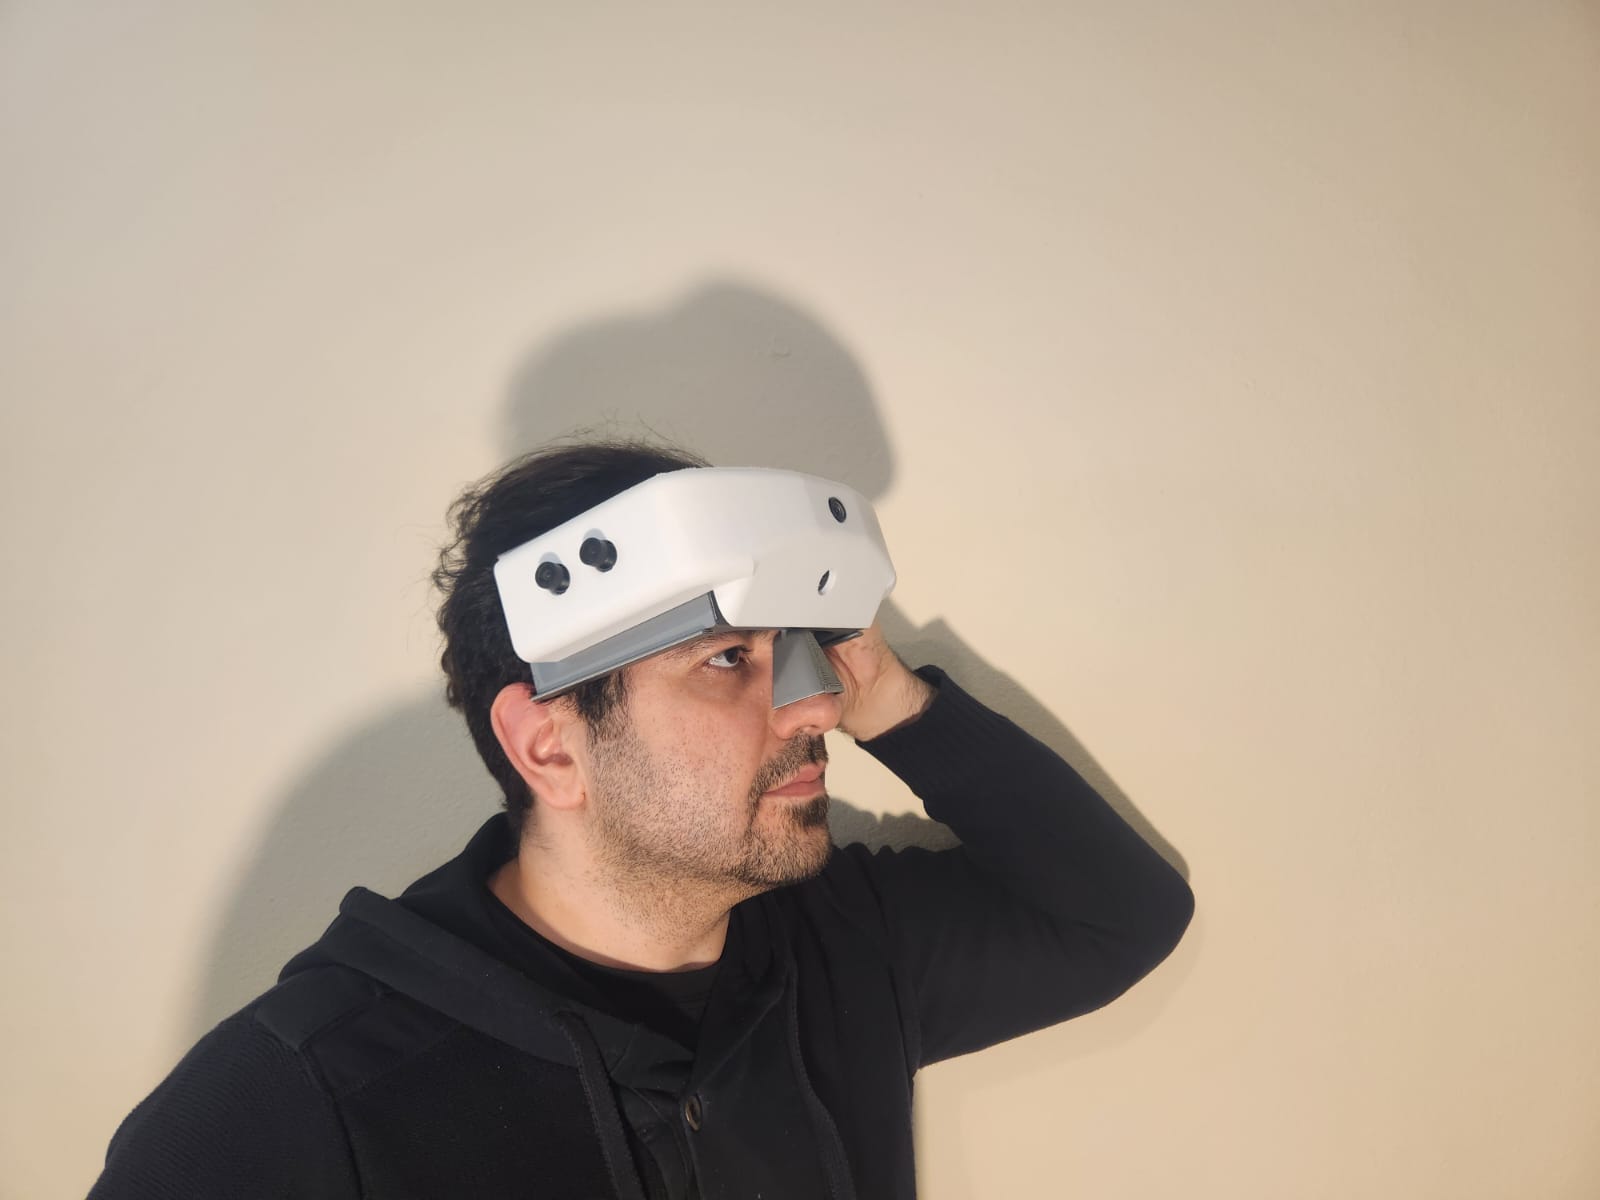
- LumiWalk — Visually Impaired Assistant Headband
Entrepreneurship project, 2019–2025 ·
lumiwalk.ai
Working prototype pairing real-time obstacle detection with voice feedback for blind users; 4× business plan competition finalist.
- AI + Global Health Hackathon
San Francisco, Dec 2024
Real-time obstacle recognition prototype using a webcam and Apple Vision Pro, built in 24 hours.
Awards & Recognition
- 1st Place Teamwork, AI + Global Health Hackathon (Dec 2024)
- Top-5 Finalist & 1st Place Sponsor Prize, Unified.to Startup Hackathon (Dec 2024)
- Health AI Bias Datathon Scholarship (Aug 2024)
- 2× I-Corps Workshop Scholarships (2024)
- Business Plan Competitions: 2× 2nd Place, 3rd Place & Finalist (2022–2025)
- Creativity, Innovation & Entrepreneurship Scholarship (2022)